How it works.
Game engines democratized game development. We are doing it for drones and robots.
What you bring, what happens to it inside the environment, and what you get back.
Bring what you build. Get back what it does.
The environment and the interfaces are the same, whichever layer is yours.
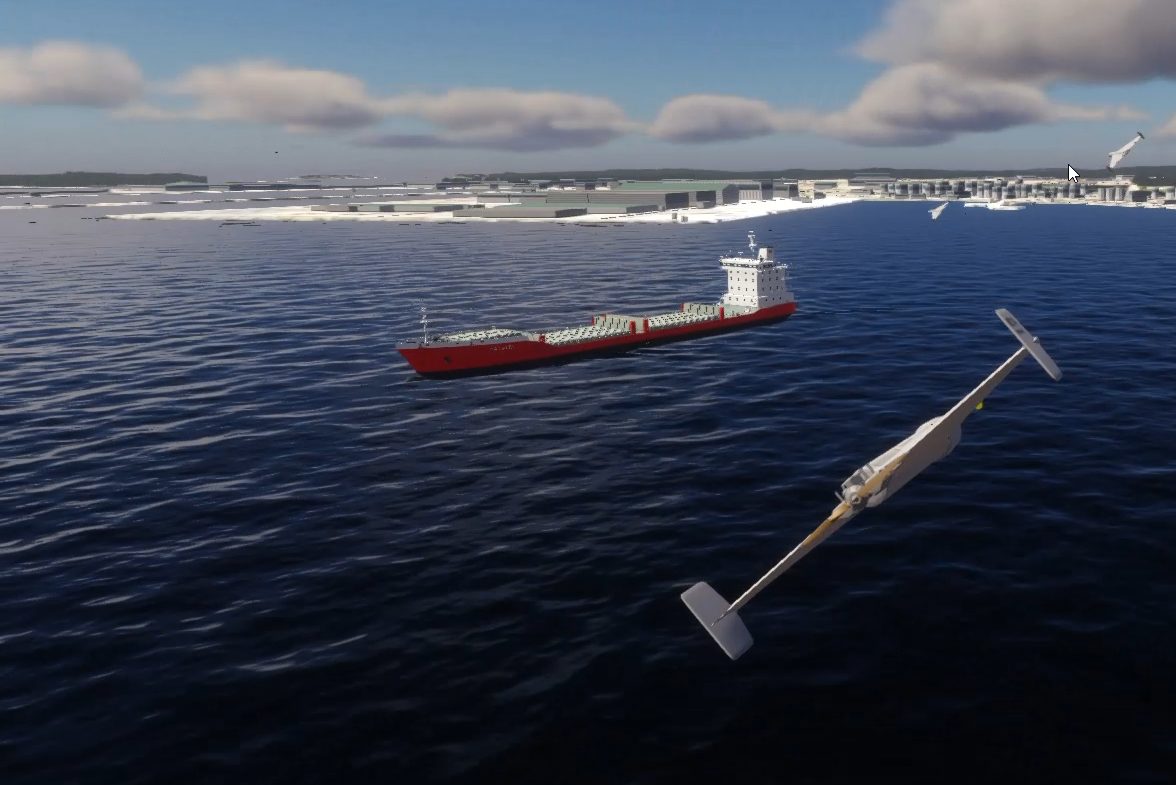
Drone, robot and component makers
Your airframe, robot, flight controller, sensor or radio.
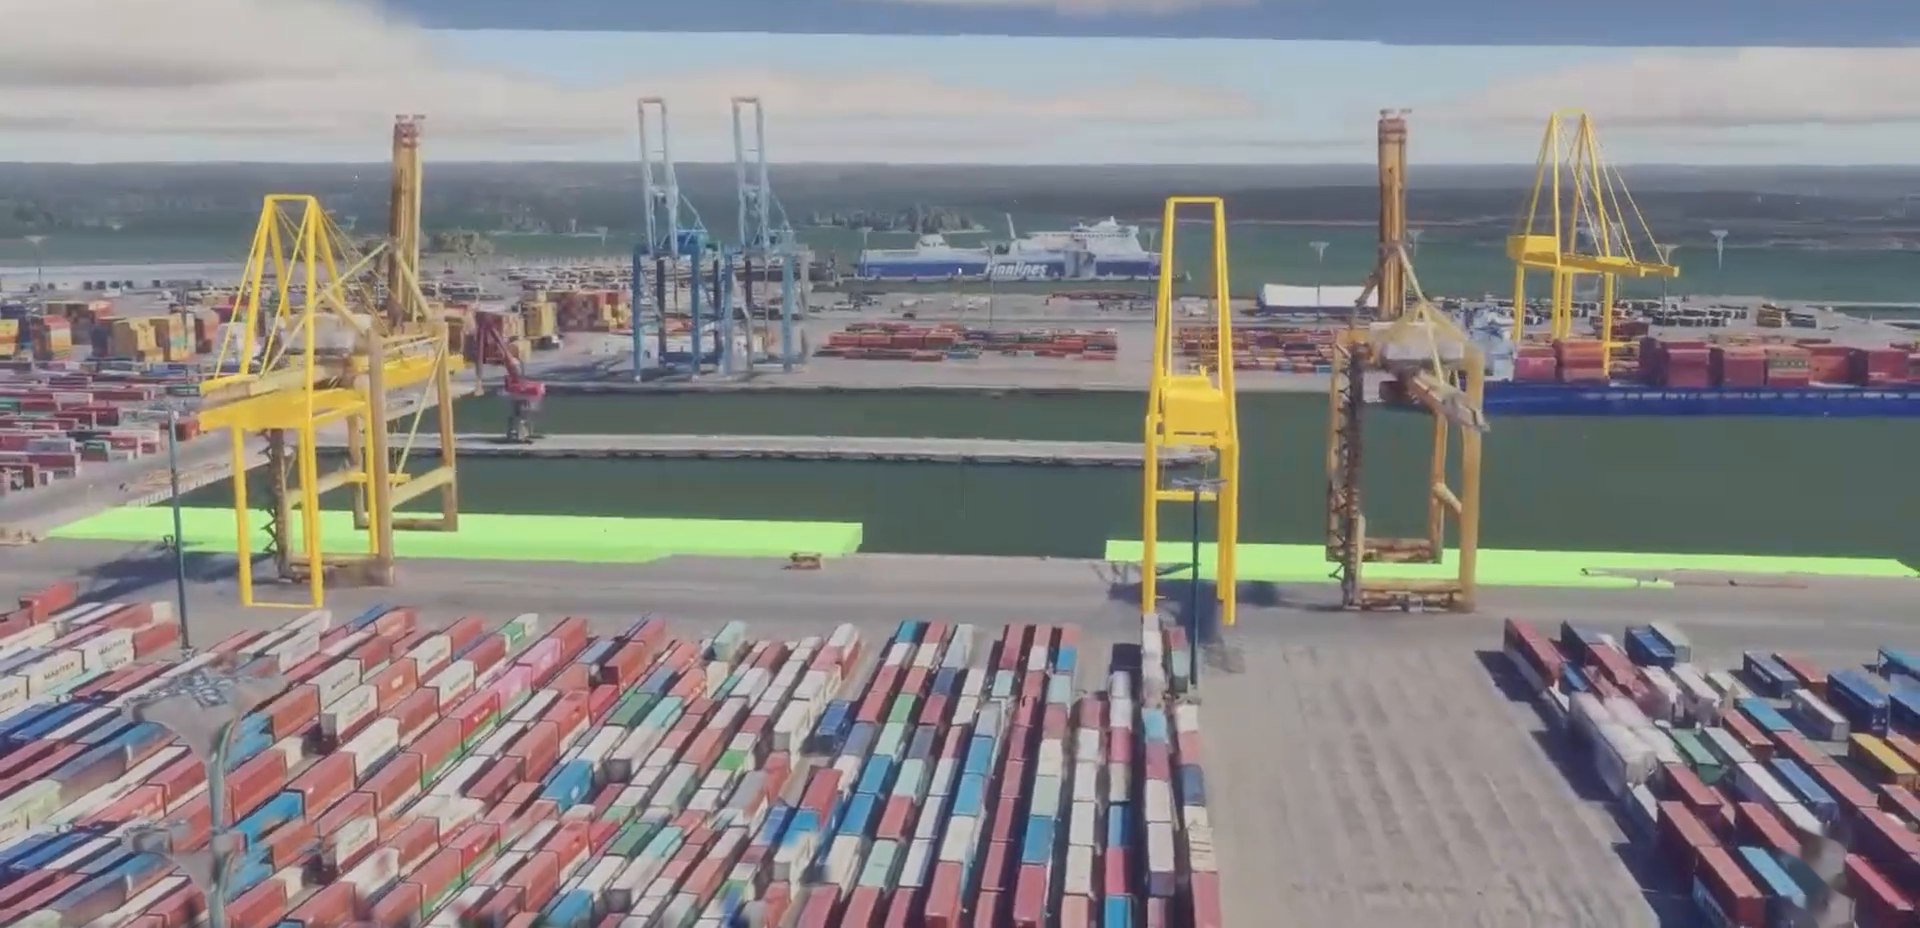
How it behaves in a real place, in the weather and traffic it will meet, before you have a permit.
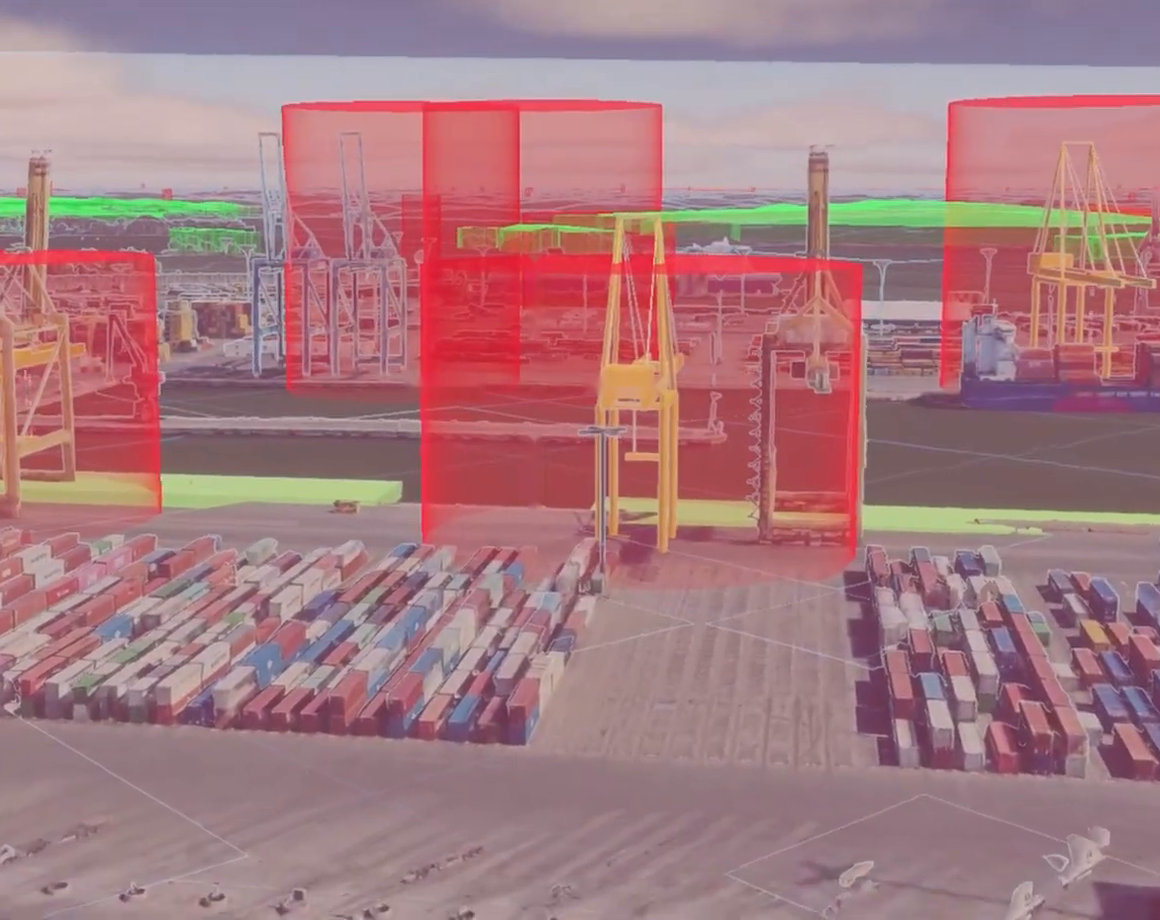
Autonomy and AI teams
Your autonomy stack, as the controller in a driving, helm, dive or flight station.
Hours of decisions in a real place, with a person able to take over mid-run.
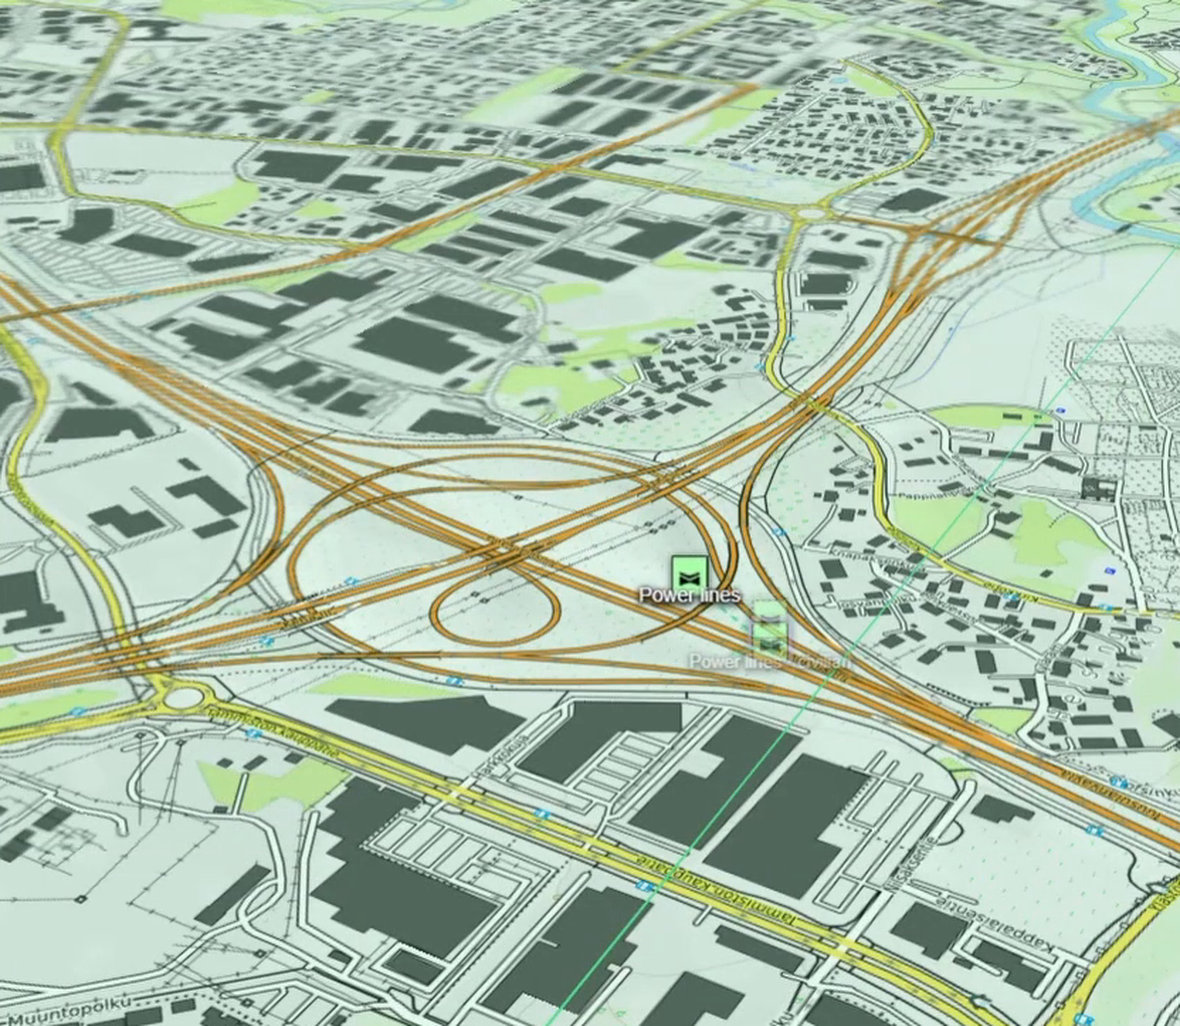
Fleet, ground control and route planning
Your planning or command software.
A whole fleet running under it, and where coordination breaks.
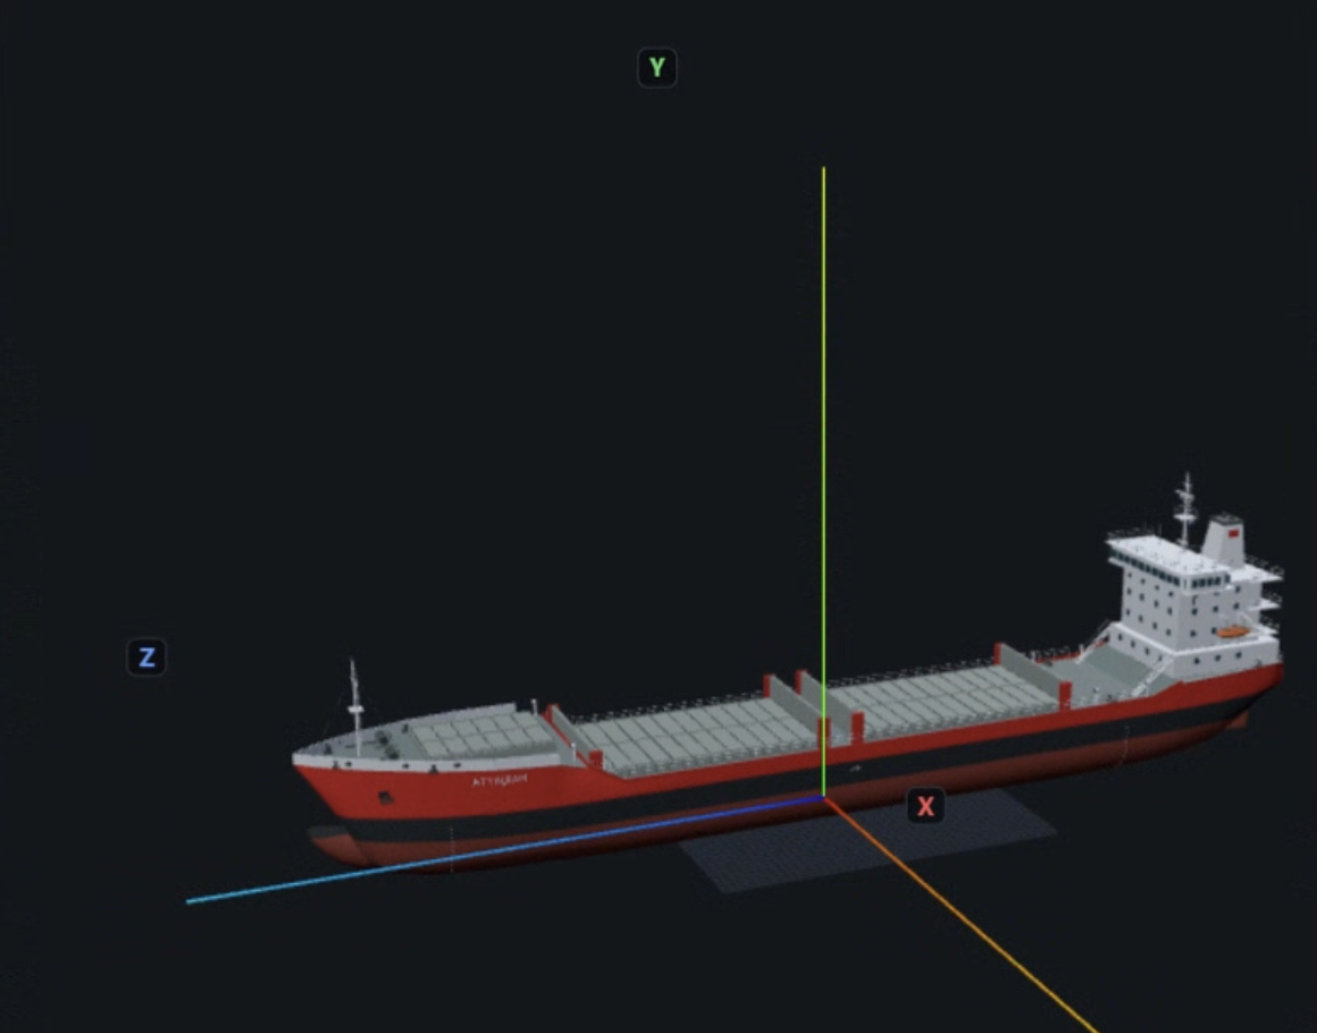
Give it the operating information and it becomes a vehicle.
Bring your own 3D model, or have an AI draft one from photos. The library grows without a modeling contract for each one.
- Sourced
- Every figure can record where its number came from.
- Rated
- And how much to trust it.
- Labeled
- Each aerodynamic figure says whether it is sourced, fitted, default or extrapolated.
Run, see, change, run again.
The aim is a short distance between a change and the evidence that it worked, before anything is cut, welded or flown.

A trial runs unattended from one command, and a script scores it. Change a setting, a condition or the whole scenario, run it again, and compare.
Arrive at test day with a system that already works.
From digital twin to software in the loop, hardware in the loop and the real device, each step cuts the technical and design errors that reach the next. ArduPilot SITL is one of the ways in.

Built to keep your code and data in Europe.
In our environment, in a dedicated one for you, or offline on your own premises. European models, or your own.
- Our environment
- A dedicated one
- Offline, on your premises
Open, and the ones you already use.
Missions stored as MAVLink mission items, the format ArduPilot and QGroundControl use.
Your autopilot firmware flies the vehicle through ArduPilot’s own simulation interface.
Camera and sensor metadata as KLV, streamed over SRT.
Scenarios defined in a published schema, checked by a live validator.
Scenarios, runs and results are designed to be reached through the same open interface, by your software or your agents.
Tell us what you need to prove.
We are building Coldrange in the open, with partners. If you build drones, robots, sensors, autonomy or ground control software, or you are responsible for the places where they operate, write to us.
Write to us hello@coldrange.aiColdrange is new. The experience is not. The team has more than a decade of building hardware-in-the-loop systems, software that talks to real hardware from drones to tanks, including projects for NATO and the British military. It also brings decades of international business experience, and a track record of successfully building and scaling ecosystem products.